Credits & Acknowledgements
Collaborators
Our team
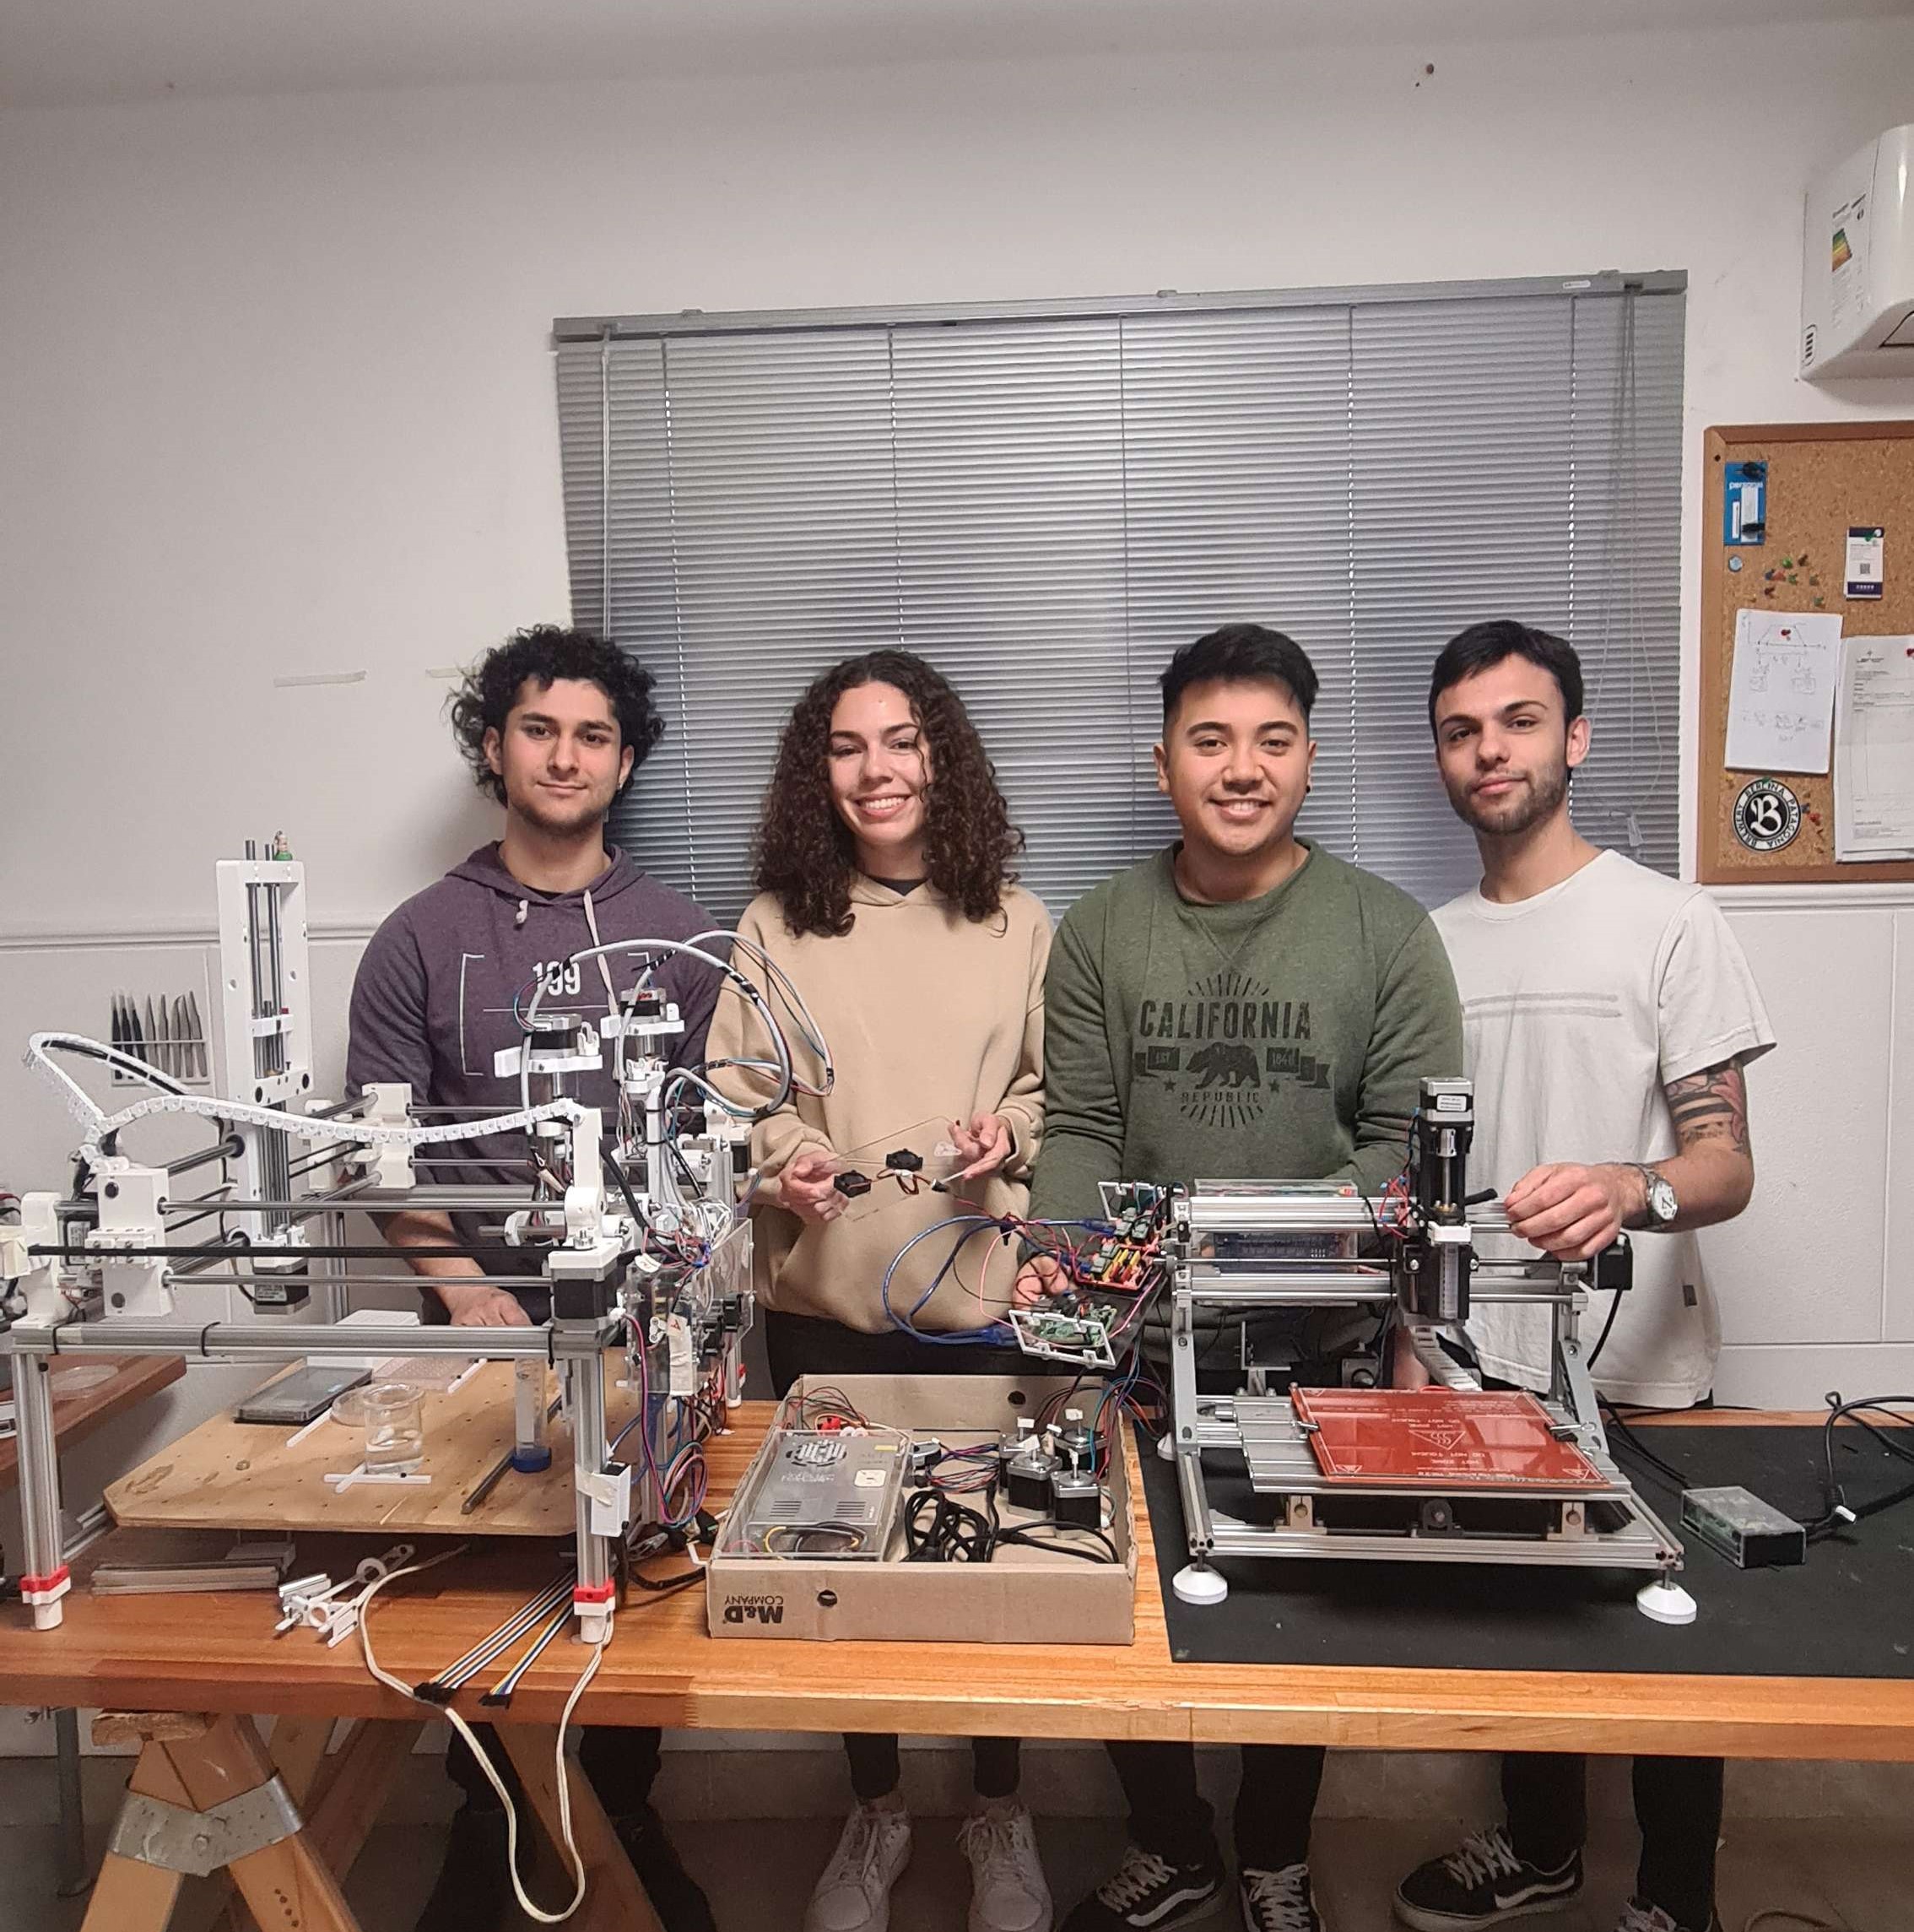
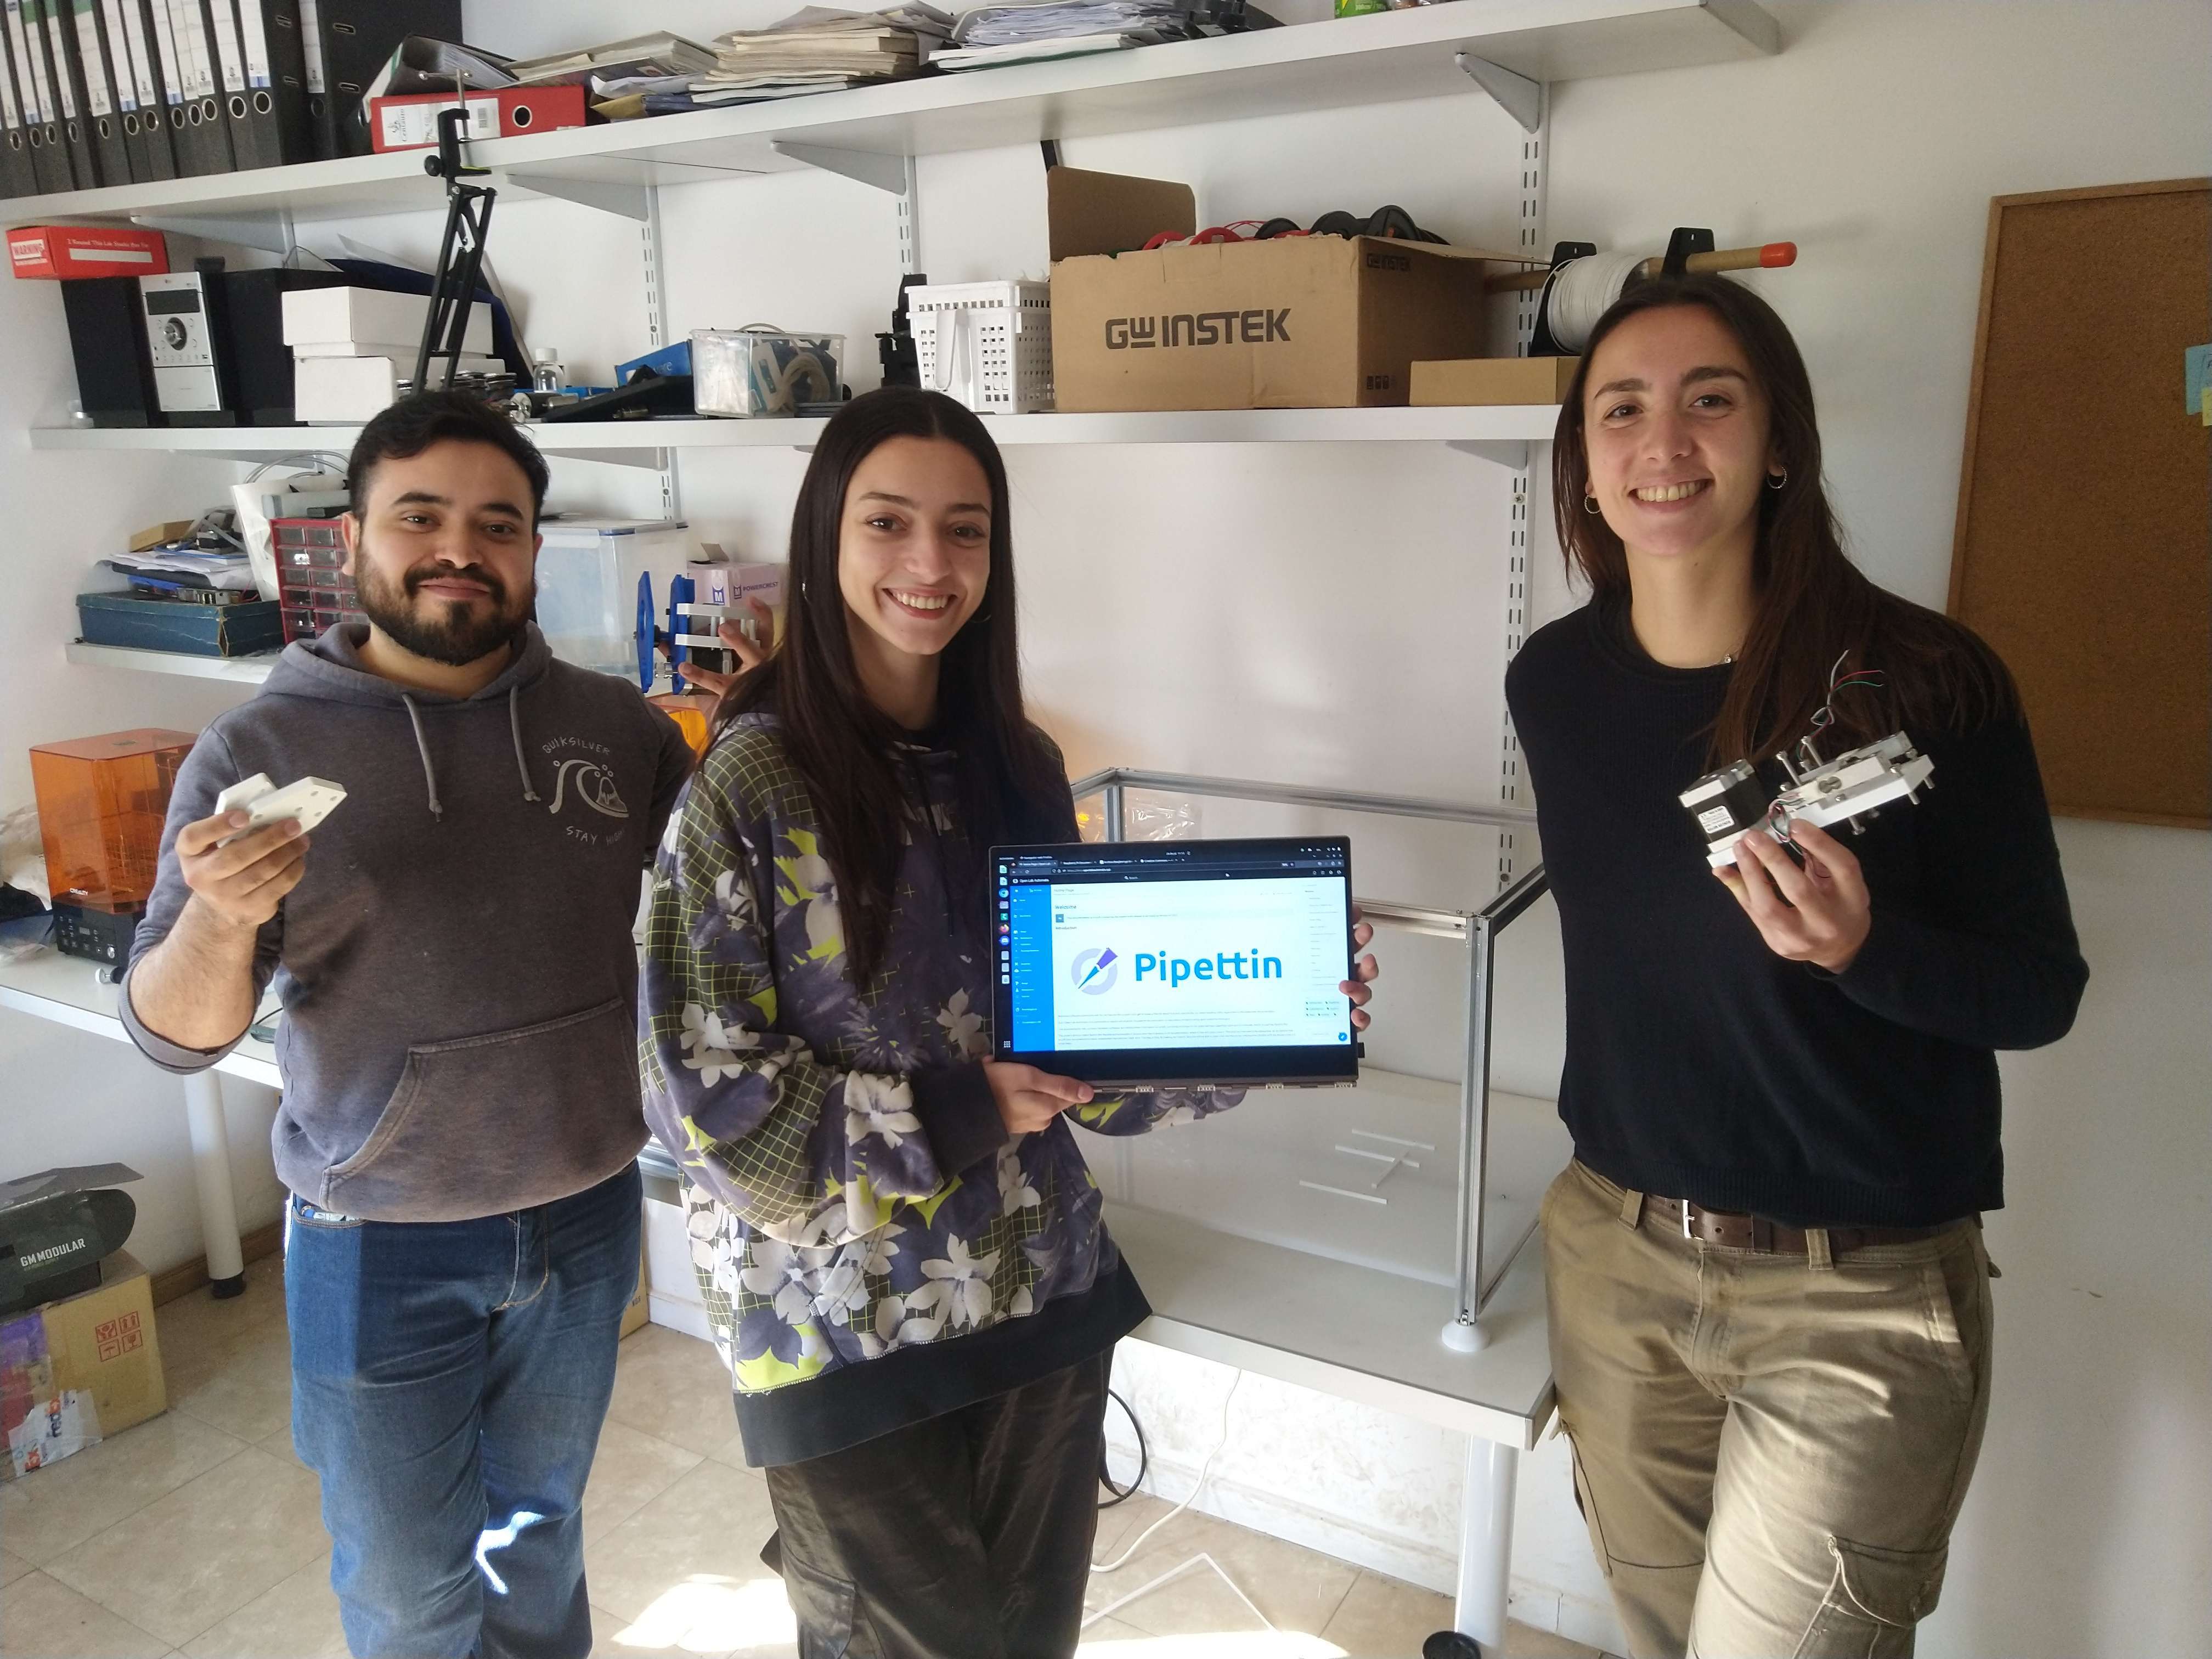
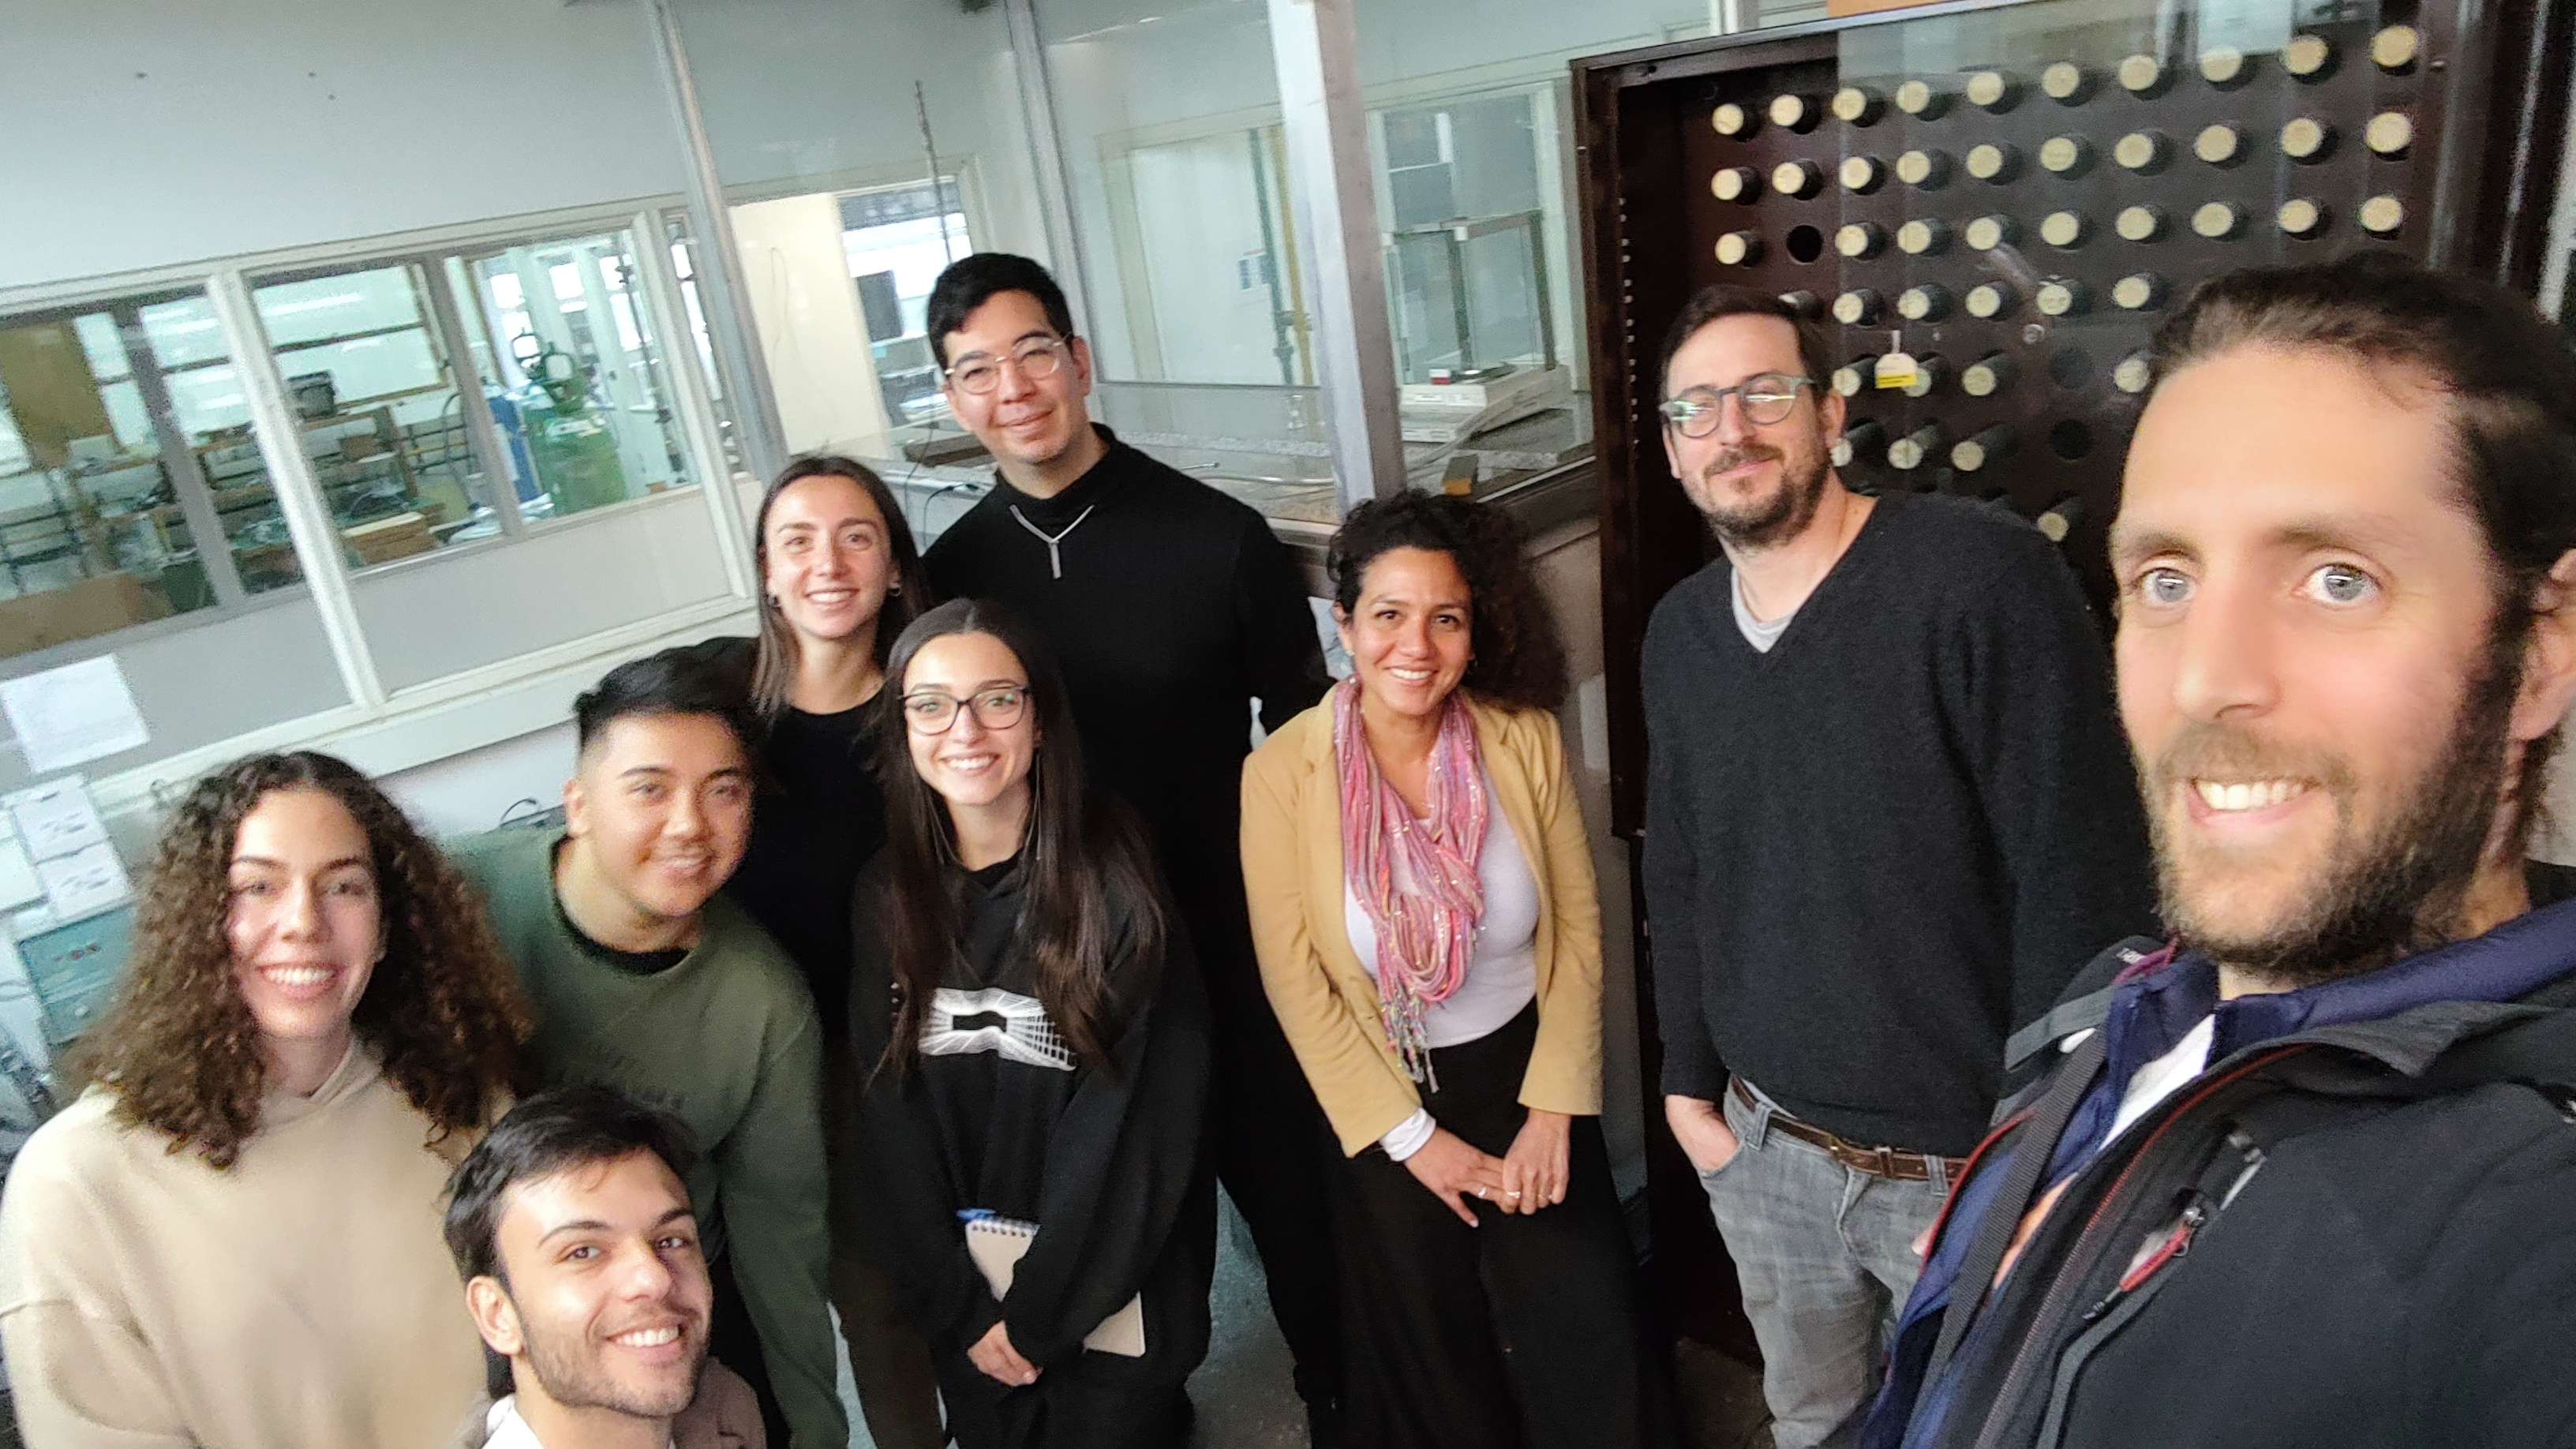
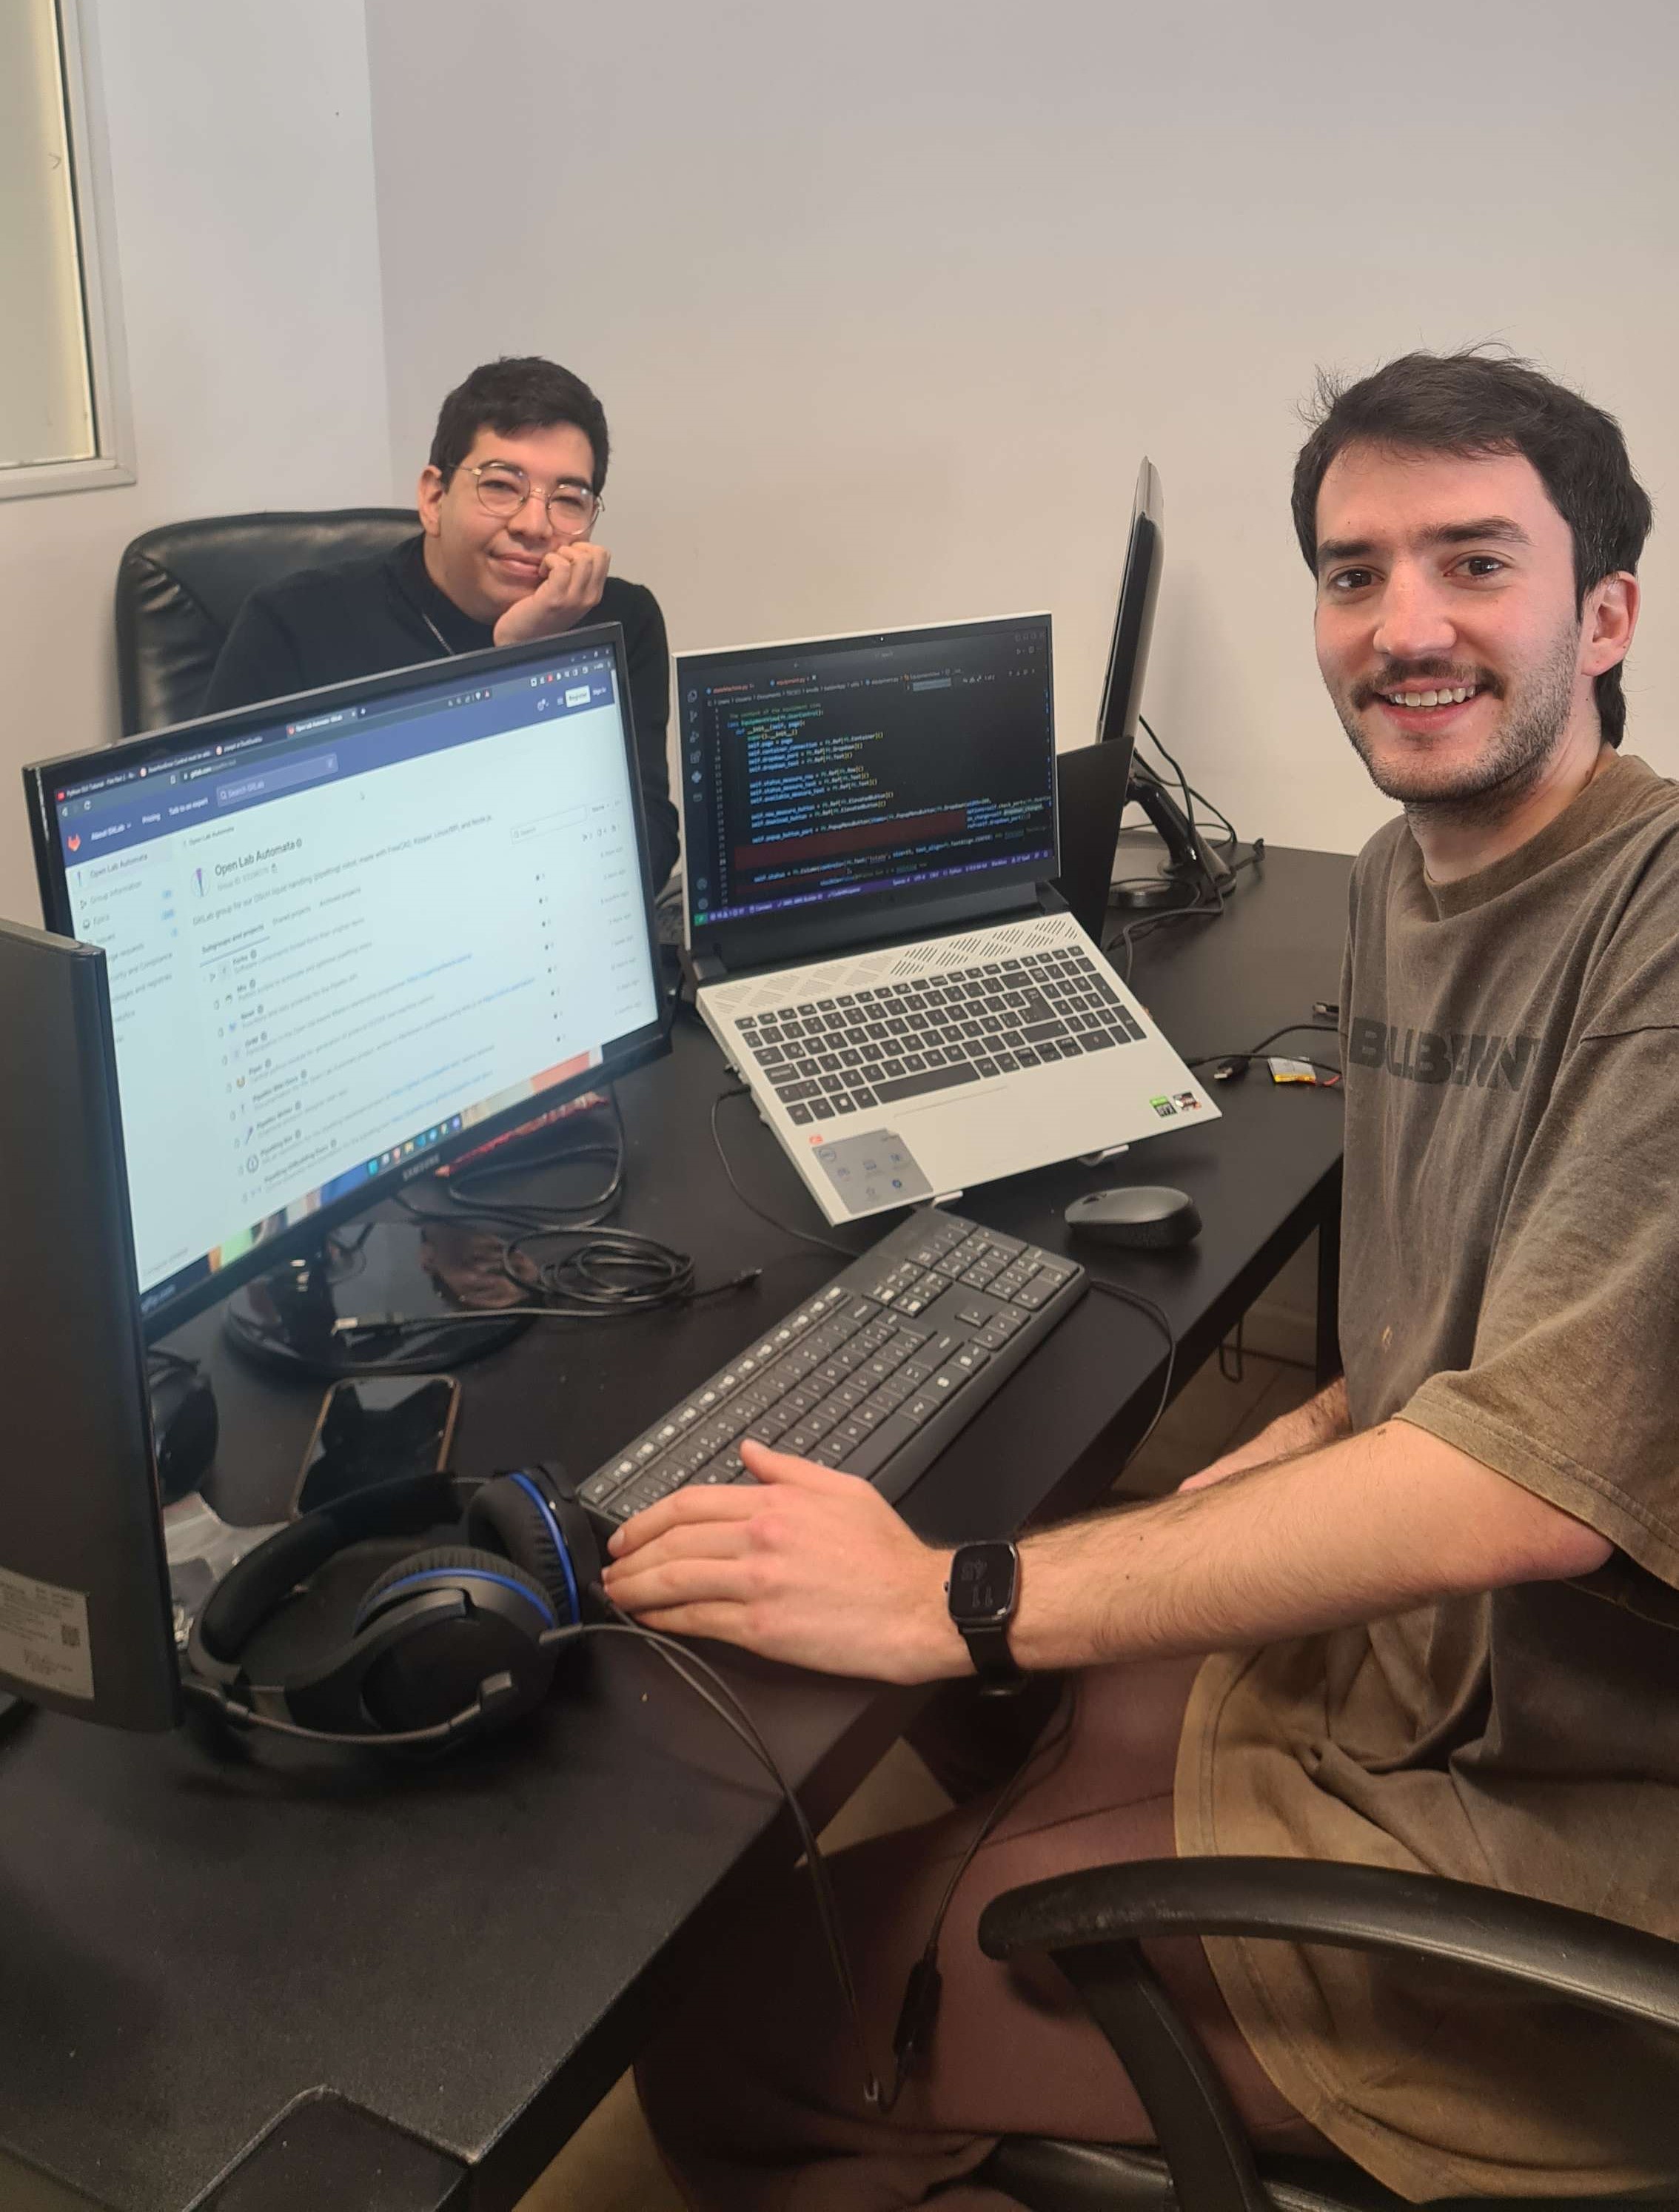
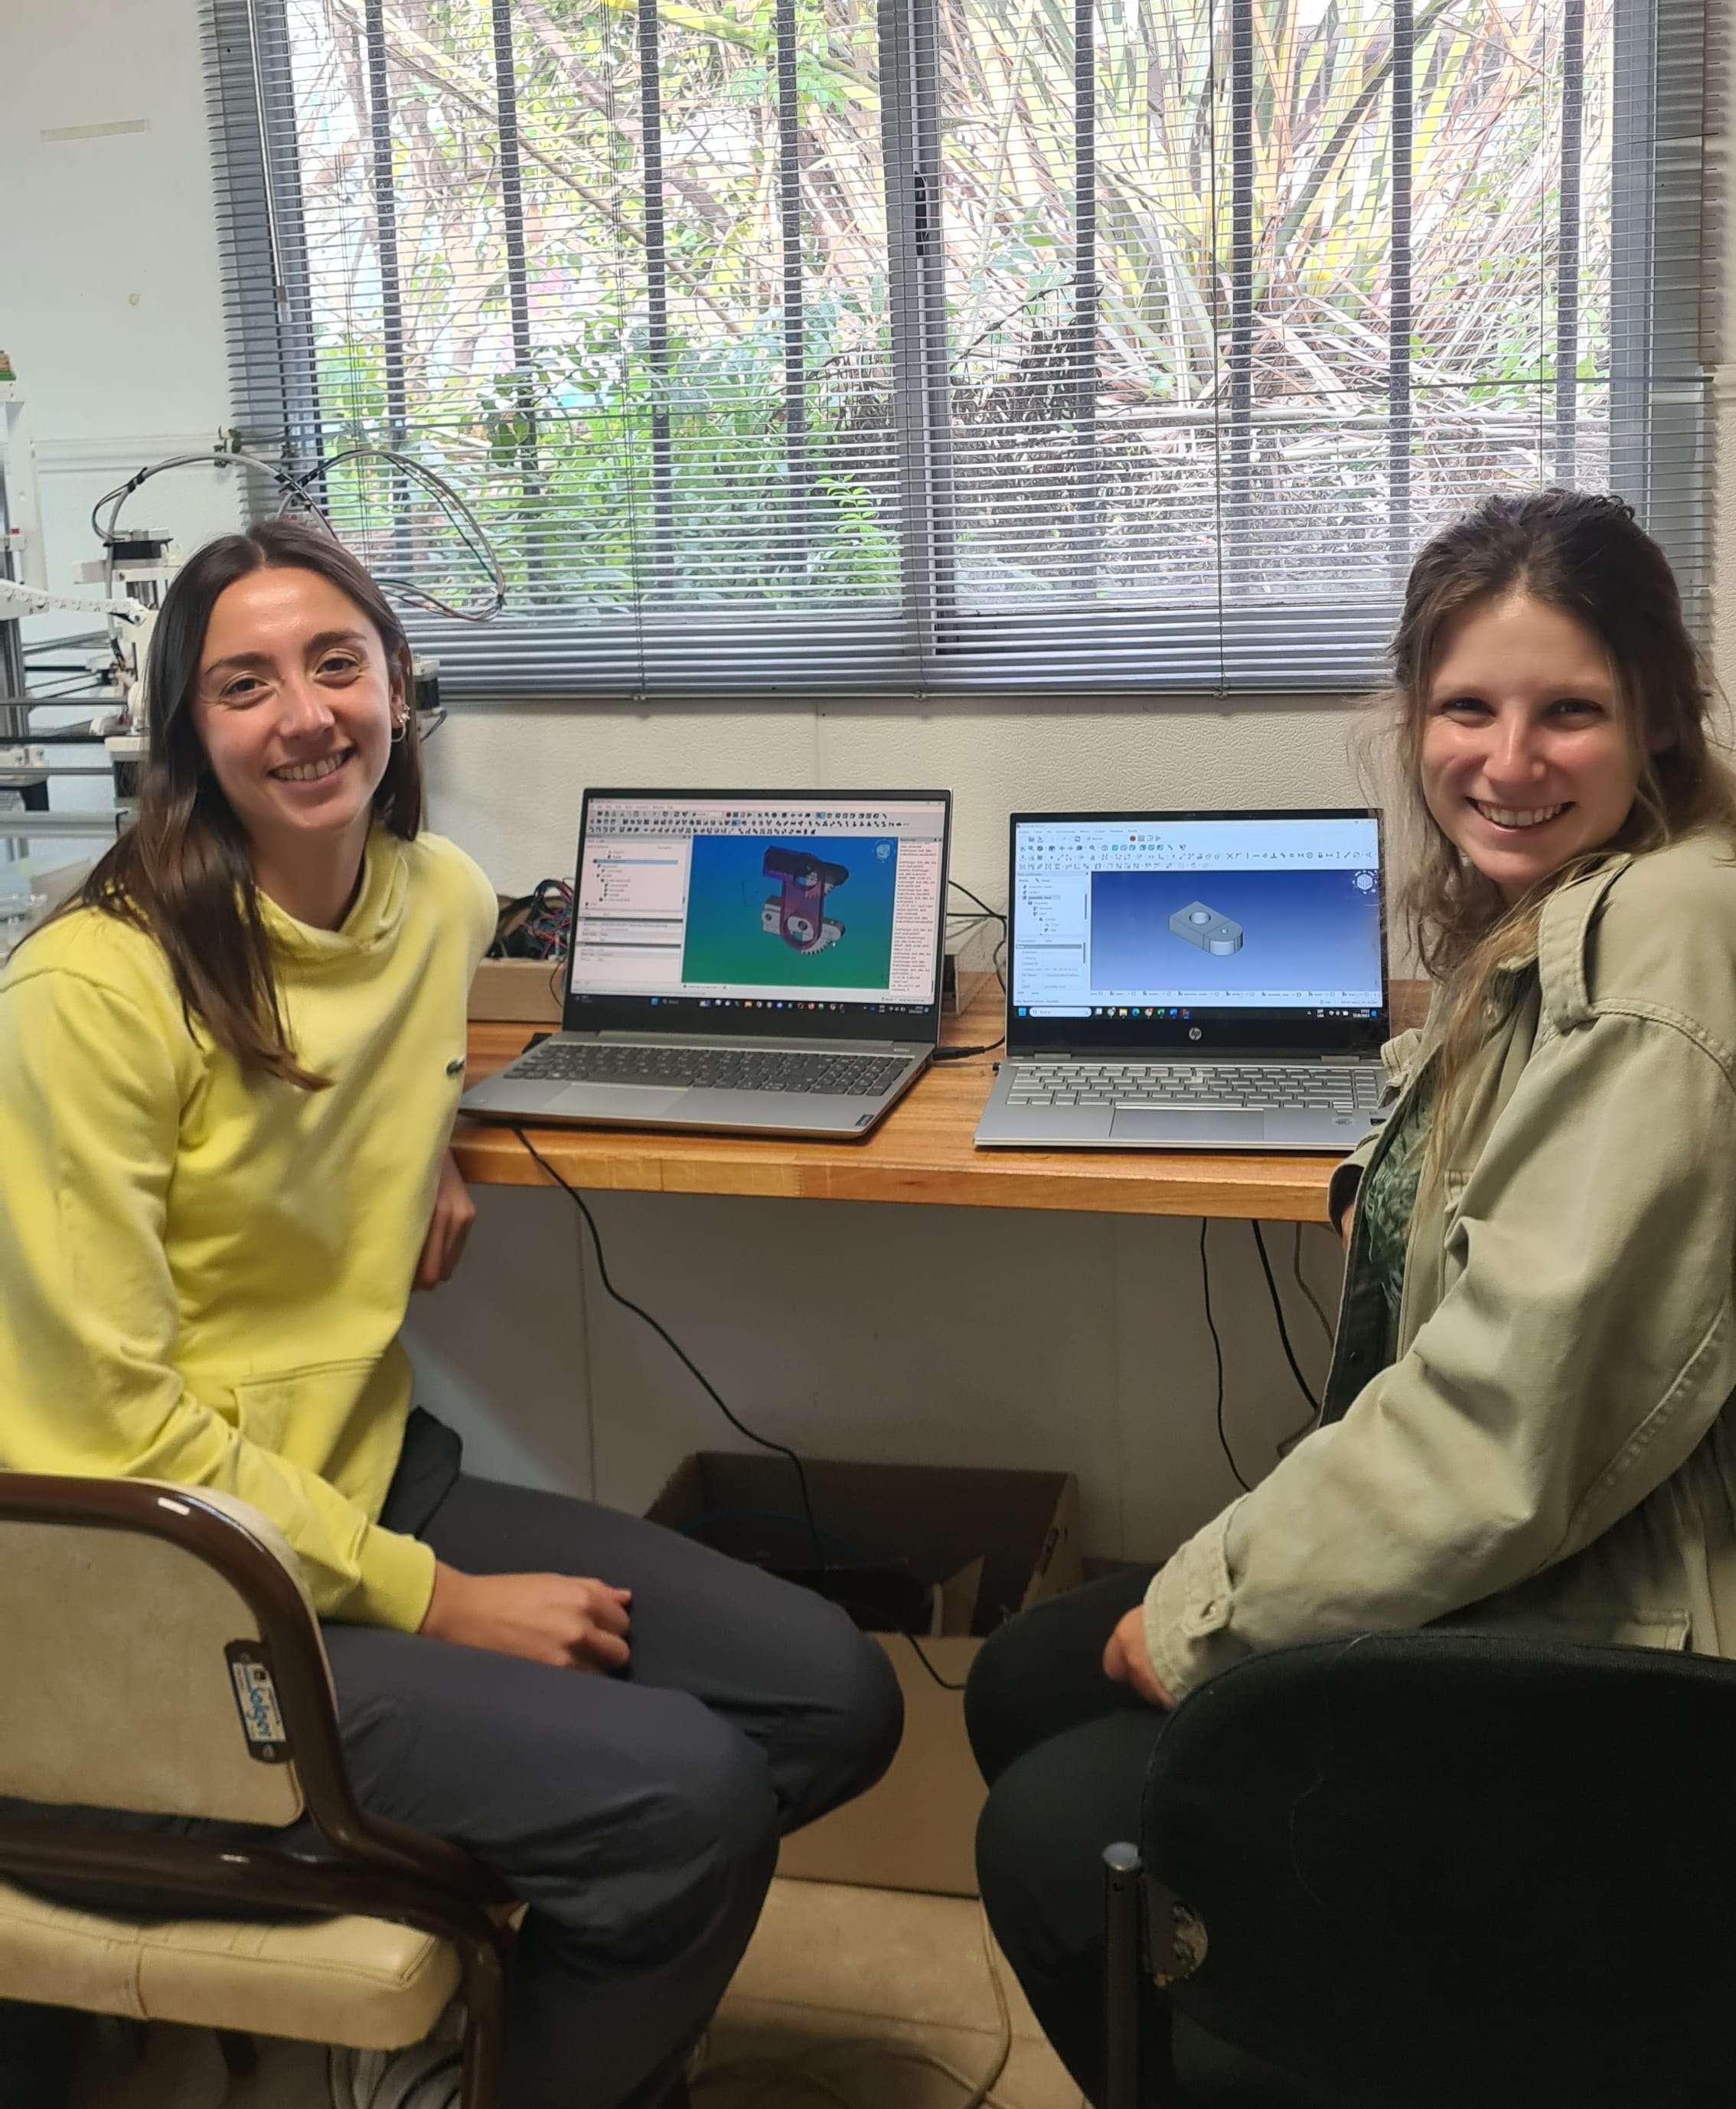
The OLA team at 2024.

Open Lab Automata: Automating labs, open-source style!
General
- Nicolás Méndez and Facundo Méndez created the project and are the lead software and hardware developers.
- Gastón Corthey co-leads the project, and hosted its development at TECSCI (S.A.S.).
Documentation
- Sofia Dinoia was in charge of all the project documentation as well as the management of social networks and dissemination channels (2024).
Software
- Nicolas Mendez and Facundo Mendez created the first prototypes, designed the database schema, and worked on conceptualization, graphic design, protocol validation, step generation, etc.
- Anka coop. were part of the team during 2022-2023, collaborating to turn the original software into a polished product.
- Zeynep Elif Tarkan (Frontend Developer) worked on many of the frontend functionalities, especially the platforms and protocols panels.
- Silvina Varela (FullStack Developer) focused on implementing the server-side functionalities, designing and setting up the API and the database. Also responsible for setting up the project structure, and managing the overall frontend architecture.
- Lucas Fernández (Frontend Developer) worked on various frontend functionalities, including the dashboard and the workspace form and list.
- This group of developers was formed by Fiqus Coop.
- Pedro Rozadas helped design and conceptualize data schemas and an API module called "Newt", meant to facilitate creating protocols and decks programatically.
Electronics
- Nicolas Mendez created the first prototypes, and designed the MK3 and MK4 hardware.
- Franco D'Alleva, Nacho Bergara, and Malena Hidalgo were members of the electronics team (2024), working on setting up motion control hardware.
Mechanics
- Pipe designed an alternate version of the tool-changer (2022), based on the GetIt printer.
- Solomon has worked on the baseplate system, and designed a nice holder for labware (2022).
- Victoria Pozzo Galdon contributed to the redesign and assemlance of the linear actuator, the tool-changer, the cartesian frame structure, and the baseplate. She also worked with FreeCAD as a design tool (2024).
- Agustin Ferreira has worked on the design of the linear actuator system and the redesign of the Y axis carriage (2024).
- Nicolas Vega (TECSCI) produced parts for the robot at the university's machine shop (2024).
Tools
- Bruno Serrentino designed the multi-stage tip holder of OLA's electronic pipette (2022), a design still in use today.
- Nicolas Mendez continued the development, testing, and volumetric calibration of the micropipette tool, and designed OLA's gripper tool.
Pictures